// 01 projects
Portfolio & Selected Work
Medtronic — Surgical Robotics

Hugo Input Arms reliability improvements

Gasket Prototypes
01 / Medtronic Surgical Robotics
Capital Hardware Life Extension
Owned mechanical changes aimed to increase the use-life of a Hugo RAS subsystem from 250 surgical procedures to 1000, including root
cause analyses, rapid prototyping / iteration, and testing while minimizing software, clinical, and manufacturing impact

Hugo Arm Cart cost reduction initiative
02 / Medtronic Surgical Robotics
Capital Equipment Cost Reduction Program
Co-led mechanical updates to reduce subsystem cost by 25% by leveraging multi-body Ansys FEA simulations, tolerance analyses given
GD&T, engineering testing, and DFA conversations with our contract manufacturer

Ergonomic Buttons Mfg redesign
03 / Medtronic Surgical Robotics
Supplier Transfers
Led dozens of vendor DFM conversations to implement mfg changes across sheet metal bent, injection molded, die cast, and machined parts

Encoder Defect Analysis

Encoder Testing Fixture
04 / Medtronic Surgical Robotics
Encoder Defect Analysis
Investigated 12+ failure modes accounting for 170+ field returns since product launch, root causing those making up 50%+ of them
Illuminant Surgical Inc

From: Illuminant.ai
01 / Illuminant Surgical Inc
Surgical Navigation System Design
Revamped the design of the surgical navigation system, reducing weight by 40 lbs, increasing stability parameters 4-fold, and decreasing
manufacturing cost by 20%

Base Plate Prototype
02 / Illuminant Surgical Inc
Base Plate Prototype
Description
MIT Device Realization Laboratory

Results section of Publication
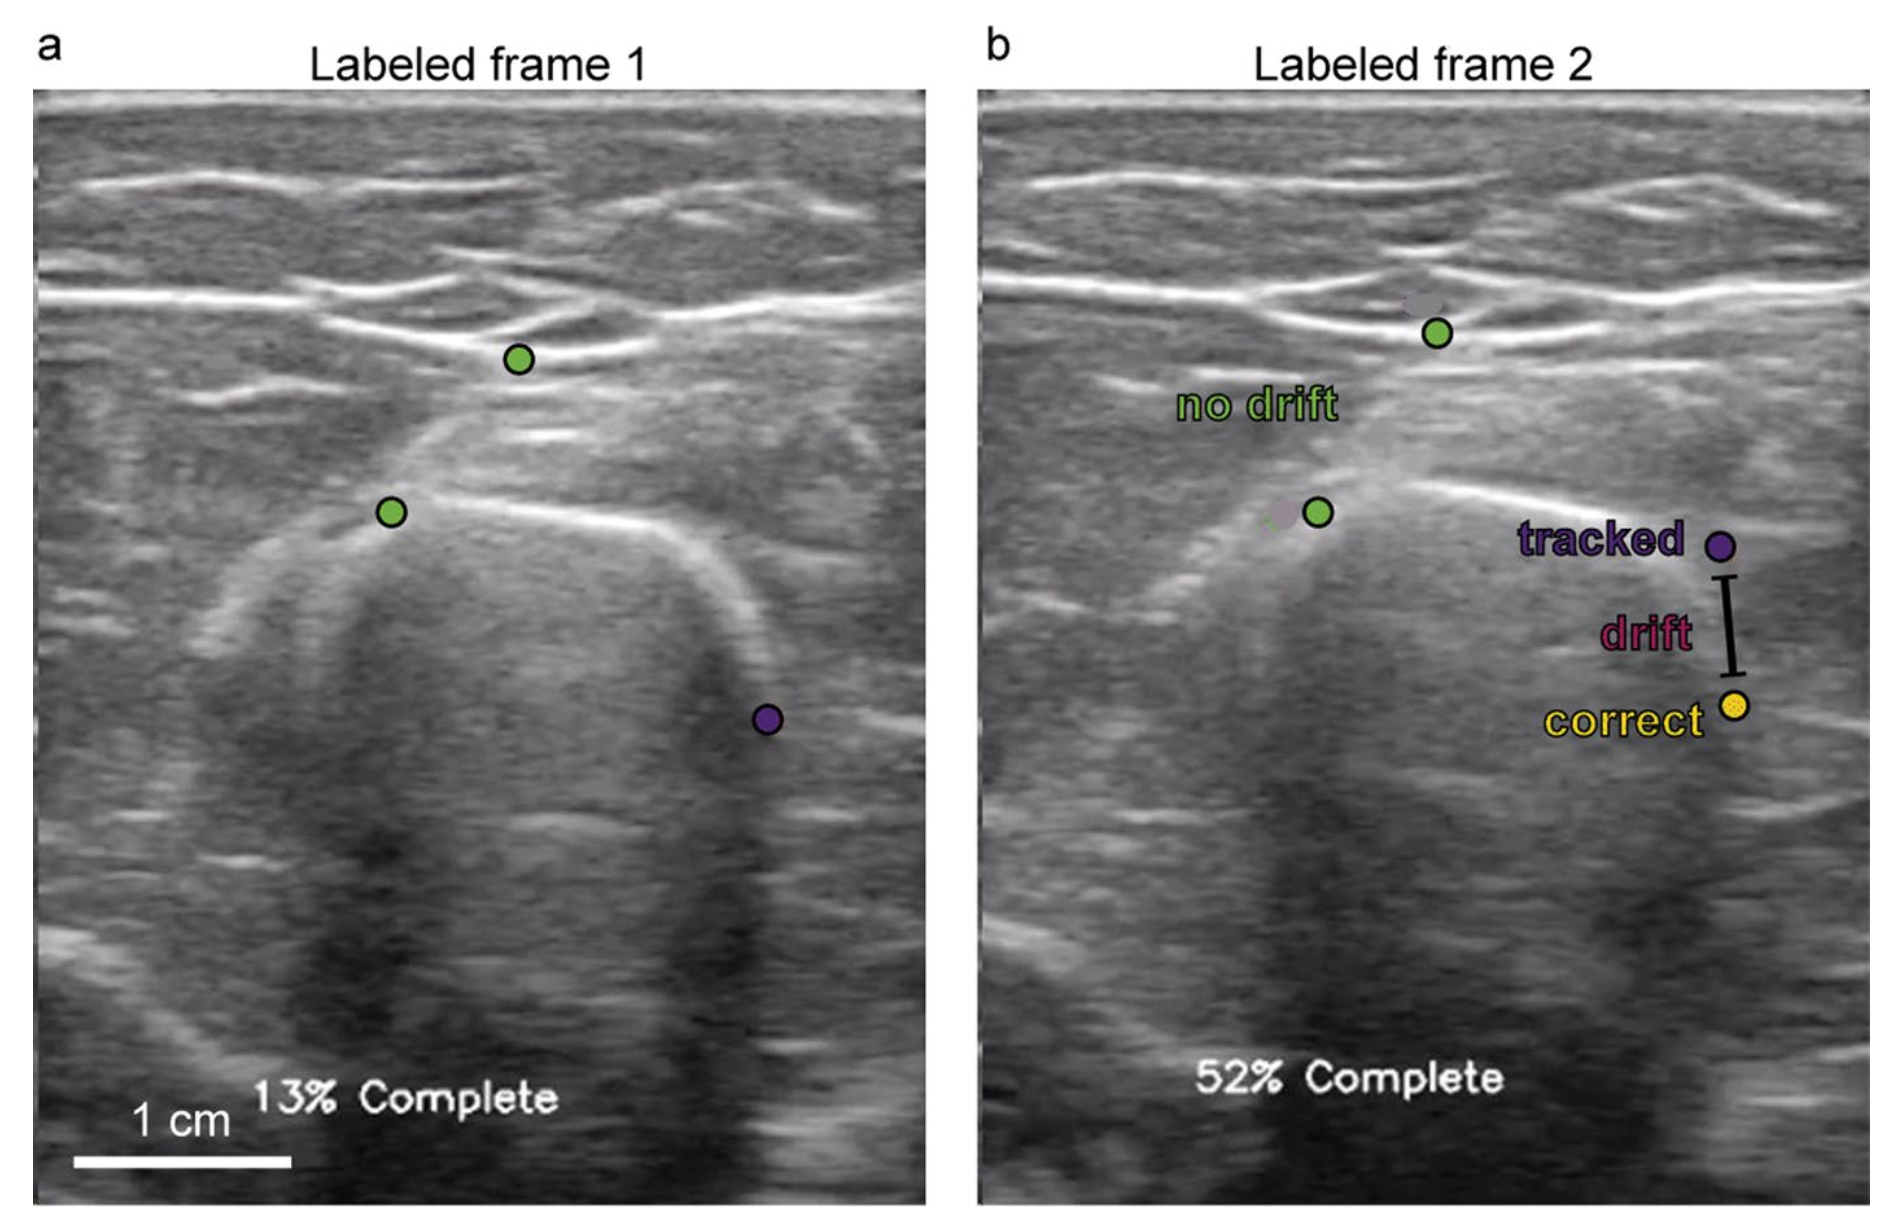
Processing labeled ultrasound data
01 / MIT Device Realization Lab
Ultrasound Feature Tracking
First-authored journal paper proposing novel frame-to-frame tracking technique of ultrasound features requiring less initial manual work,
but matching accuracy Deep Neural Network computer vision algorithms, published in the BioMedical Engineering Online journal
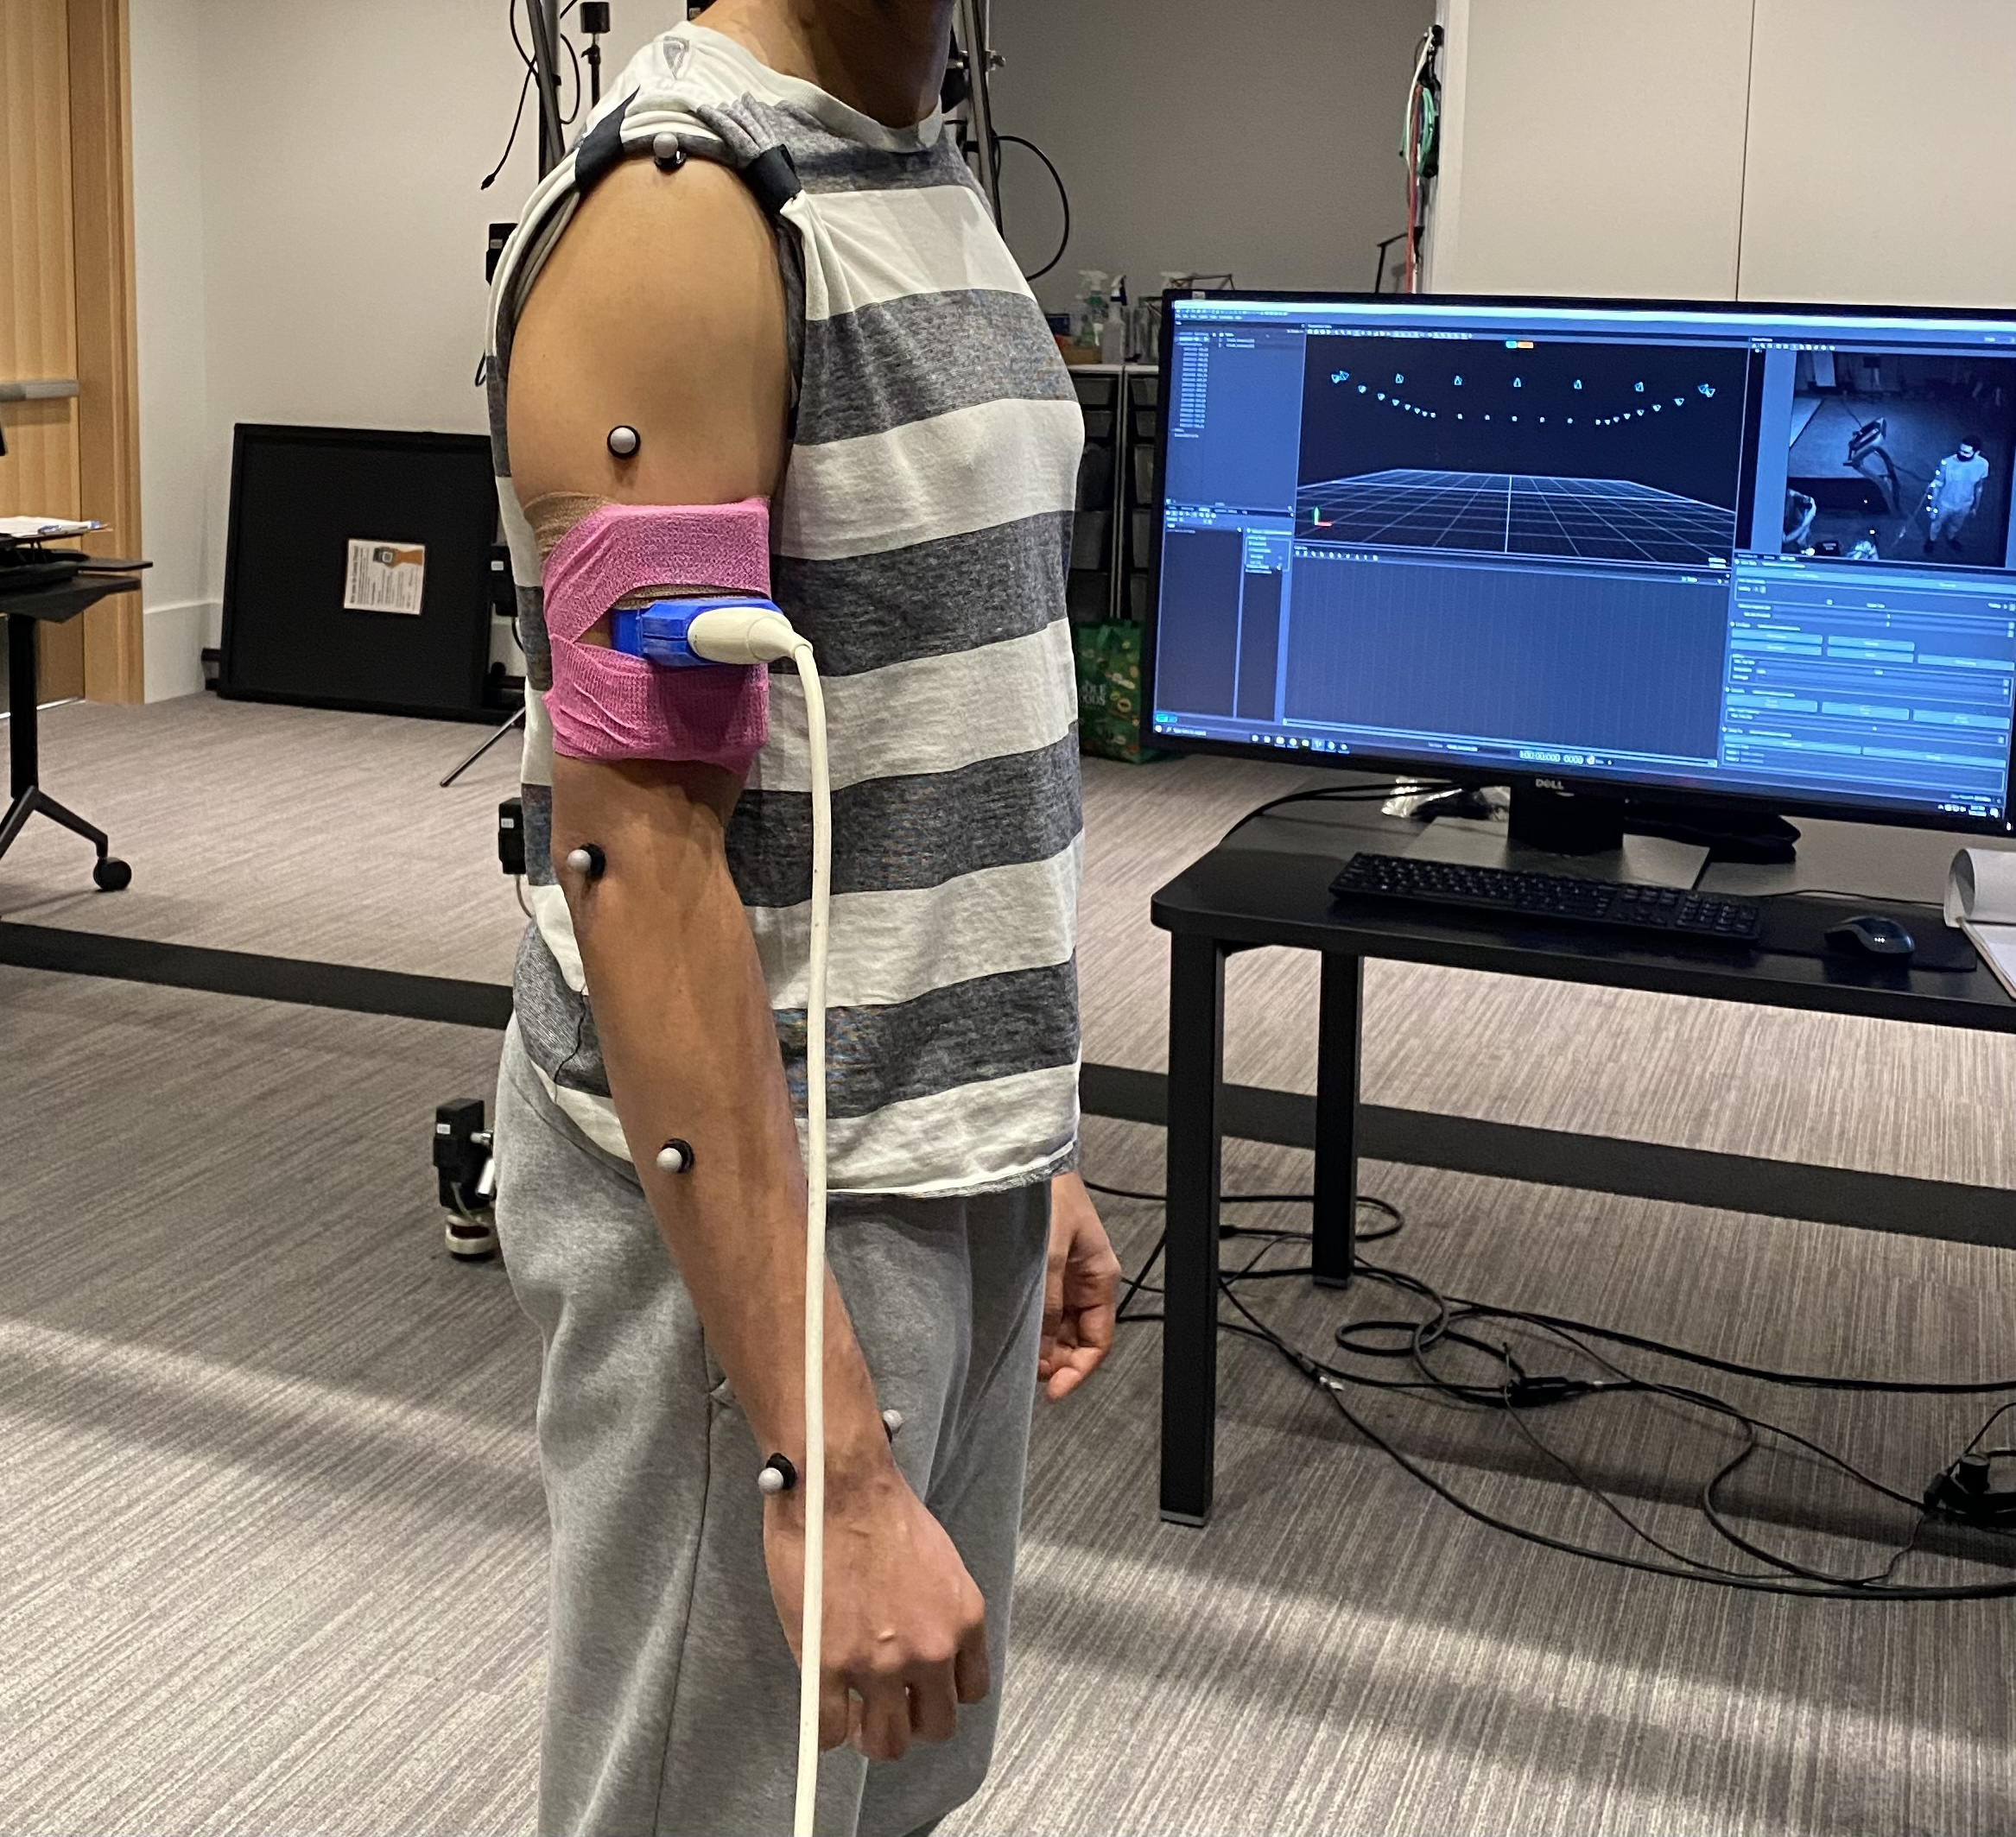
Setup for ultrasound data collection
03 / MIT Device Realization Lab
Human Study
Designed and conducted human study with 26 subjects, analyzing physiologic data from 20+ skin-adhered sensors and markers
04 / MIT Device Realization Lab
Python Code Repository
Developed Python code repository for MIT Immersion Lab to facilitate the post-processing and feature-tracking of ultrasound videos
Used signal processing techniques (full and windowed fast Fourier transforms, Welch’s method) of accelerometer signals for tremor detection
Myomo Inc

Fixture for mounting orthotic system

Fixture for testing orthotic system boards
01 / Myomo Inc
Orthotic Robotic System — Fixtures & Attachments
Designed a robust cycle-testing mechanical fixture for Myomo's powered orthotic system using low-cost and 3D-printed components.
Modeled, 3D-printed, and redesigned 5 robotic system attachments to improve ease-of-use. Delivered a certified testing protocol
covering fatigue, excessive deflection, and impact tests.